|
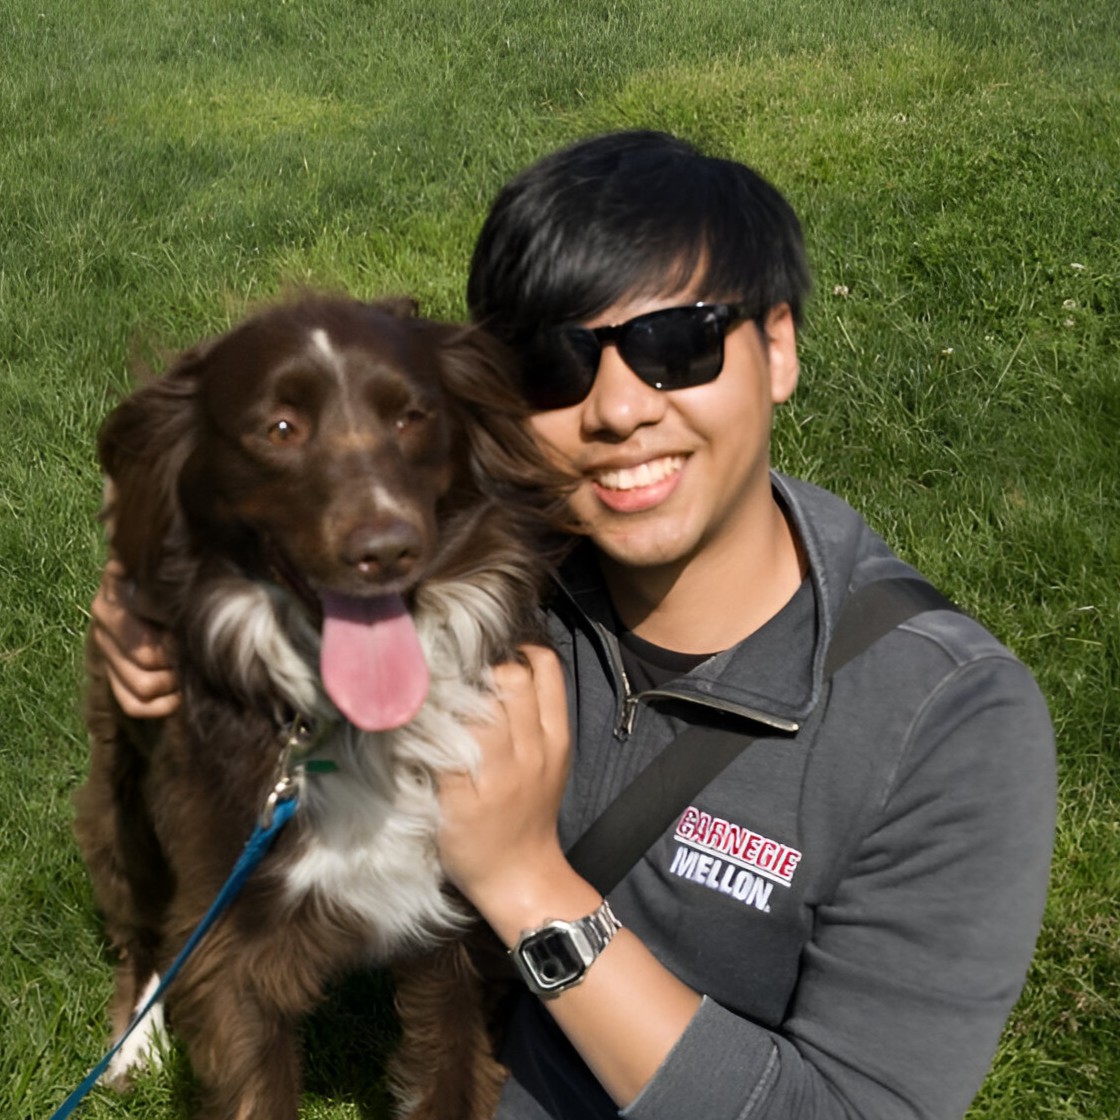
Rian Borah I'm a student in the Robotics Institute (RI) at Carnegie Mellon University in the MRSD program. My research interests are in Robot Learning, Reinforcement Learning, Optimal & Robust Control, and Computer Vision. I graduated with a B.S. in Computer Engineering from UC Santa Cruz. |
|
ResearchI am currently working on a project focused on 3D reconstruction of egocentric video data to create simulations for robot policy training. |
Experience |
|
SyncQ — VP of Engineering
New Delhi, India | May 2025 – July 2026 Led engineering, operations, strategy, sales, and development. |
|
SOLO World Partners — Robotics & Computer Vision Engineer
Detroit, MI | Oct 2024 – Apr 2025 Transformer-based vision models for warehouse and logistic QA for automotive components and ERP integrations. |
|
TDK InvenSense — Engineer Intern, SmartRobotics Team (R&D)
San Jose, CA | Jun 2024 – Sep 2024 Developed embedded sensor fusion algorithms for inertial navigation and haptic teleoperation systems. |
|
Rolandi Bioelectronics Lab — Undergraduate Researcher
Santa Cruz, CA | Jan 2023 – Jun 2023 Developing bioelectronic devices for intelligent control of wound regeneration, under the DARPA-BETR program. |
Education |
|
Carnegie Mellon University — Pittsburgh, PA
M.S. in Robotic Systems Development (MRSD) Robotics Institute — School of Computer Science Aug 2026 – May 2028 | GPA: 4.0/4.0 |
|
University of California, Santa Cruz — Santa Cruz, CA
B.S. in Computer Engineering (Concentration: Digital Hardware) Baskin School of Engineering Sep 2021 – Mar 2024 | Graduated in 2.5 years |
|
Delhi Public School, R.K. Puram — New Delhi, India
High School, May 2021 — CBSE | (Sciences + CS) 96.6% |
Selected Projects |
|
Sep 2026 – Dec 2027 3D reconstruction of egocentric video data to generate evaluation-ready simulation environments for robot policy training. |
|
|
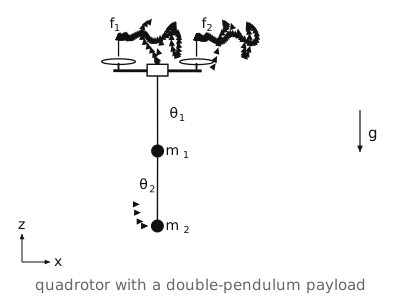
Deep RL-based Control of a Quadrotor with Double Pendulum Payload
Oct 2026 – Dec 2026 Training model-free deep RL algorithms (PPO, SAC, TD3) to learn controllers for underactuated, chaotic dynamics. |
|
F1Tenth – Autonomous Racing
Aug 2026 – Sep 2026 1/10 scale autonomous racing with reactive methods and RRT* for path planning & obstacle avoidance. |
|
|
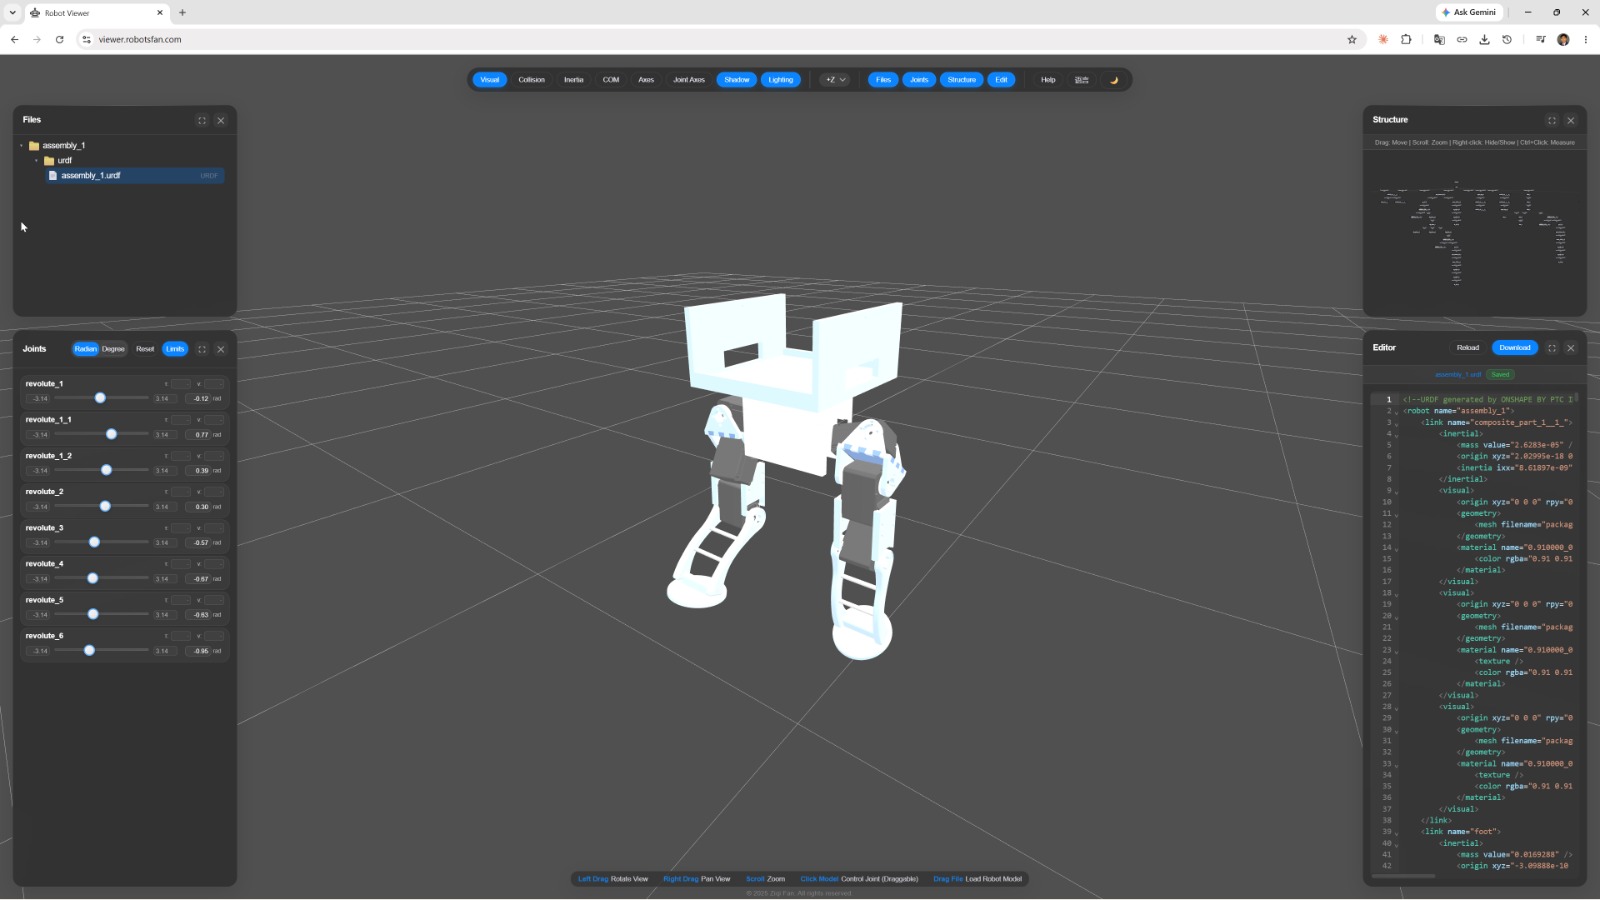
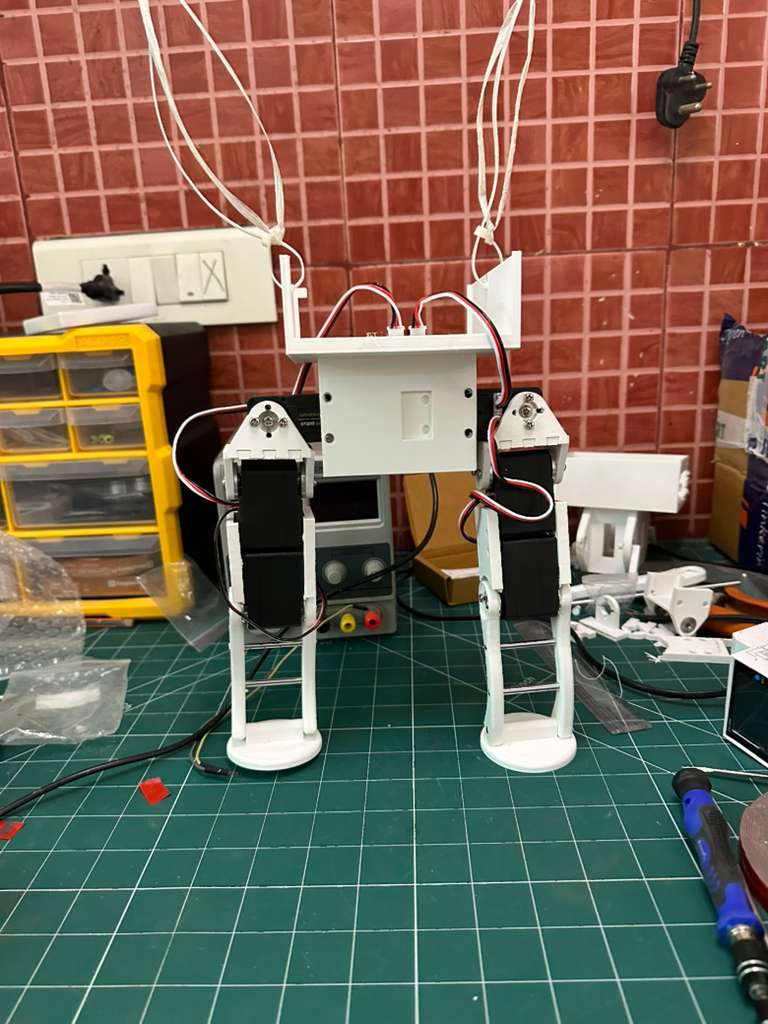
Bipedal Robot – Hardware Design & Locomotion via Reinforcement Learning
Jun 2026 – Aug 2026 Designed & fabricated a 6-DoF biped. Trained end-to-end RL locomotion policies in mjlab using PPO. |
|
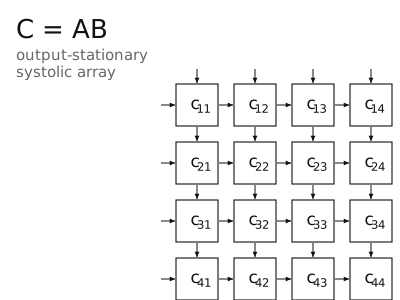
DNN-MatMul Accelerator (TPU / Tensor Processing Unit)
Jan 2024 – Mar 2024 Built a parametric systolic array generator for arbitrary matrix multiplication via HW/SW co-design in Chisel HDL. |
|
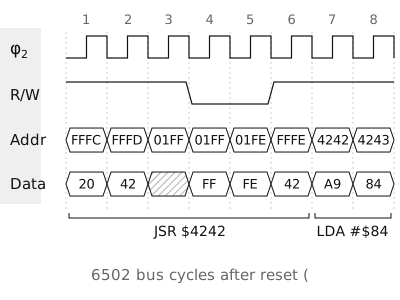
6502 Emulator
Aug 2023 – Present Cycle-accurate 6502 emulator in C++. |
|
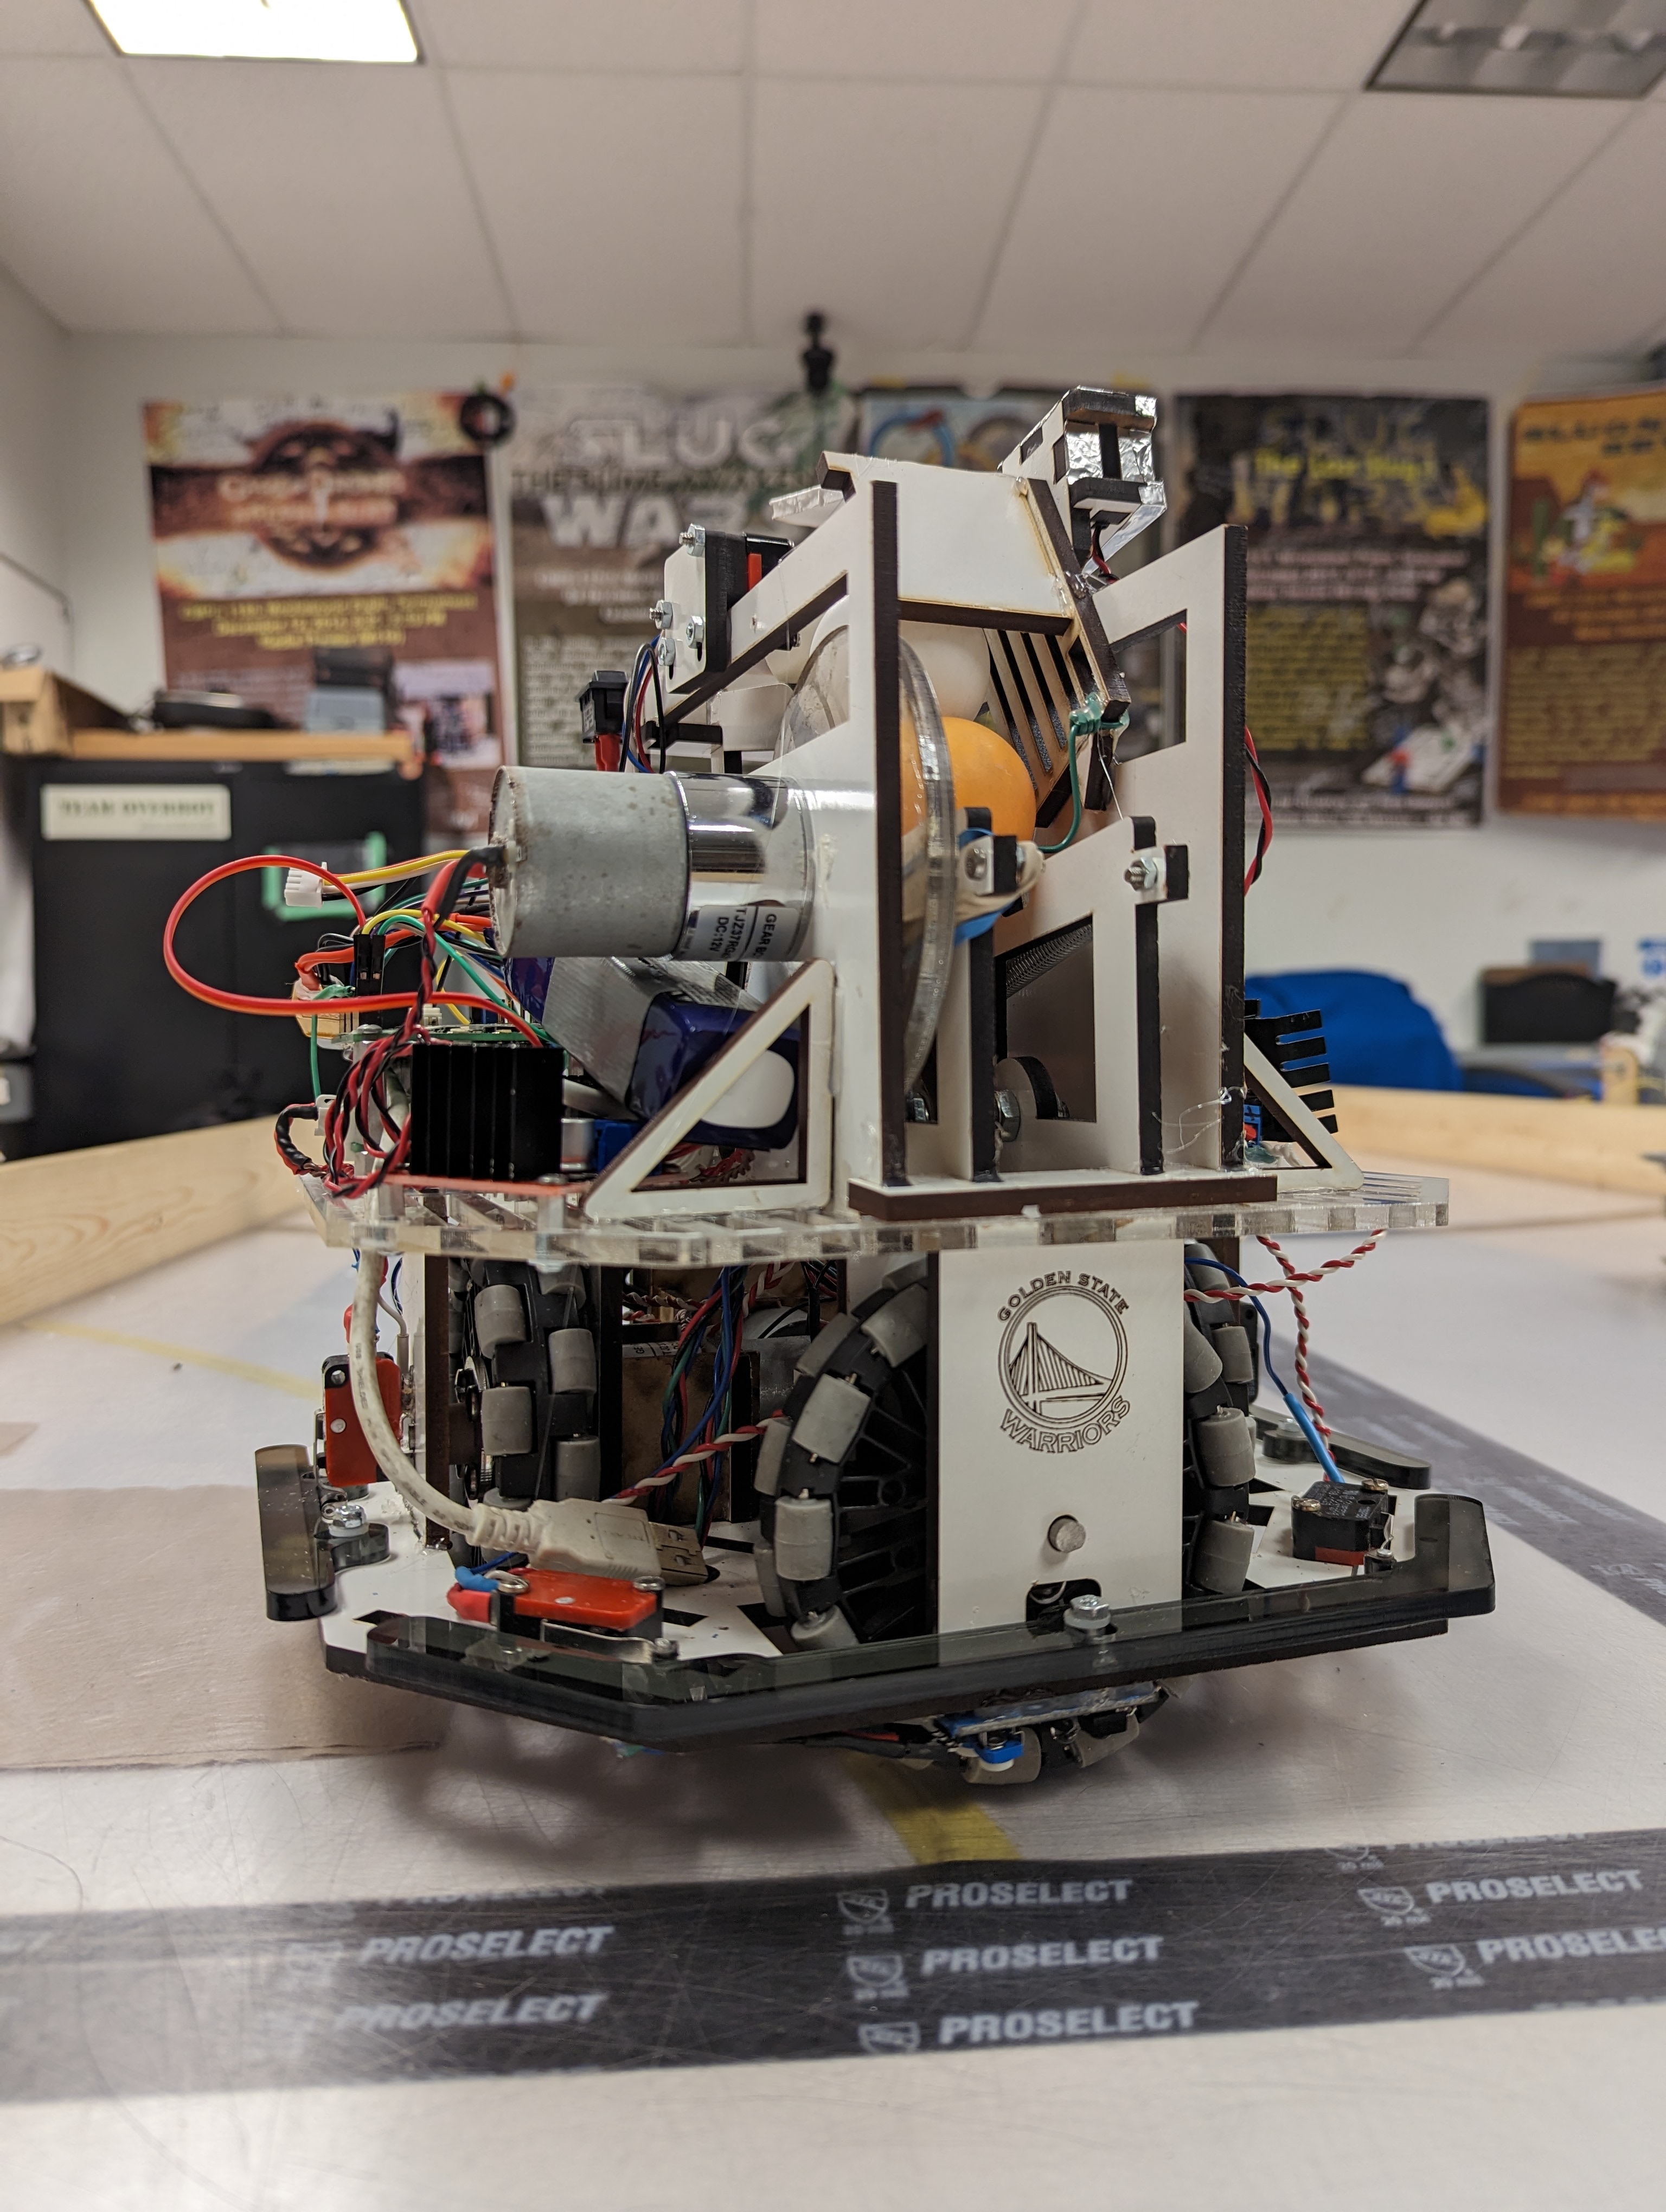
Autonomous Soccer Robot — UCSC, B.S. Capstone Project
Jan 2023 – Mar 2023 Fully autonomous robot for miniature soccer with a custom RTOS/event-driven scheduler, feedback-controlled omni-wheel drive, and analog IR detectors with Chebyshev filters. |
Honors & Awards
|
TeachingCSE 120: Computer Architecture (RISC-V) — Undergraduate Group Tutor ×2, UC Santa Cruz |
|
Website design from Jon Barron — source code. |